RoboParty Launches RP1 in Southeast Asia, Bringing Full-Stack Open Robotics to Education and Research
With RP1 and RPO, RoboParty offers open humanoid platforms spanning hands-on education, foundational
Loading...
SHANGHAI, Oct. 16, 2026 /PRNewswire/ -- RoboParty today announced RP1 (ROBOTO 01), a high-performance, full-stack open-source humanoid platform for robotics research and embodied AI development. Combining access to core hardware and software with modular configurations, RP1 enables researchers to examine how the robot works, modify its systems and adapt it to their projects.
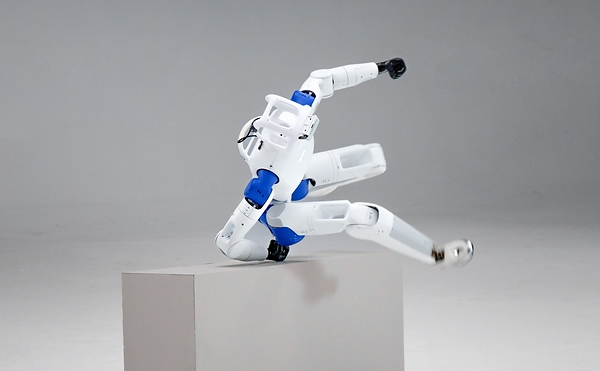
Researchers need to understand how hardware, control systems and learning algorithms interact, and how changes across those layers affect physical behavior.
RoboParty believes embodied AI should not be built on technological black boxes: every researcher should have the freedom to explore. By sharing engineering resources and development tools, the company aims to make one team's work a foundation that others can examine, extend and improve.
Full-Stack Open Source: From Hardware to Deployment
RP1's development stack spans mechanical structures, electronics, ROMOMO actuator technology, motion control, simulation, training and deployment. Technical documentation and research materials connect the robot's physical construction with the software that turns algorithms into actions.
Sharing these layers lets researchers work beyond predefined interfaces. When physical behavior differs from an algorithm's intended output, researchers can investigate the hardware, control methods and models involved. Access to control interfaces and execution feedback supports comparisons between training results and physical experiments, helping teams identify problems and refine their approaches.
PartyOS, under continuing development by RoboParty Lab, brings together motion control, motion retargeting and learning tools. Higher-level perception, interaction and task capabilities remain subject to further integration and validation, with additional software components planned for staged open-source release.
Designed for Research: Adapting the Robot to the Project
The Standard version stands approximately 1.3 meters tall and has 24 active degrees of freedom, supporting gait, balance and simulation-to-real research. RP1 Pro has 30 active degrees of freedom, including a two-axis neck and seven axes per arm, providing configuration options for end-to-end policy research, human-robot interaction and embodied data collection. Both counts exclude dexterous-hand degrees of freedom.
Interchangeable head modules and wrist-mounted end effectors, together with the RP Hand dexterous hand and expandable computing options, allow teams to configure the platform around manipulation and model-development experiments. Open-source hardware and software resources support modifications as research requirements change.
Teams can compare control methods on the same hardware or retain a method while investigating hardware changes. Robot models, software configurations and experiment records help researchers trace those differences and support repeated testing under documented conditions.
This gives teams a shared platform for different research questions, while keeping changes and test conditions visible. Each configuration still requires matching models, control settings and validation for the intended task.
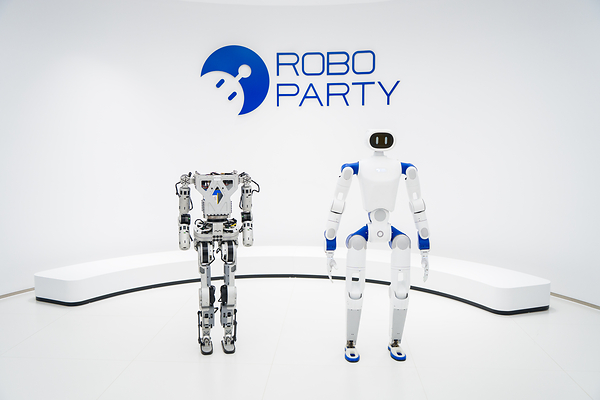
About RoboParty
Founded in Shanghai in 2025, RoboParty develops humanoid hardware, motion control, software and open-source tools for robotics research and embodied AI development.
Github: github.com/Roboparty/RP1
Web : roboparty.com
Media : [email protected]


